REPORTS & TECHNICAL DELIVERABLES
[ Open-Source Software Stack, Technical Design Report & Engineering Research ]
TECHNICAL DESIGN REPORT (TDR)
Comprehensive technical paper detailing the mechanical hull design, power distribution, safety architectures, ROS 2 navigation stack, and multi-domain vehicle integration.
SYSTEM DEMONSTRATION VIDEO
Official video submission demonstrating autonomous navigation, buoy obstacle avoidance, subsea acoustic tracking, E-Stop safety systems, and pool trial executions for Proof of Readiness.
Open-Source Maritime Robotics Stack:
Our entire software suite developed at PUCP is public, modular, and open-source. Hosted on GitHub, it includes complete packages for ROS 2 navigation, MAVLink drivers, SeaTrac USBL acoustic positioning, custom PyQt control dashboards, and Gazebo/VRX simulation environments.
Explore RobotX PUCP GitHub Repository →
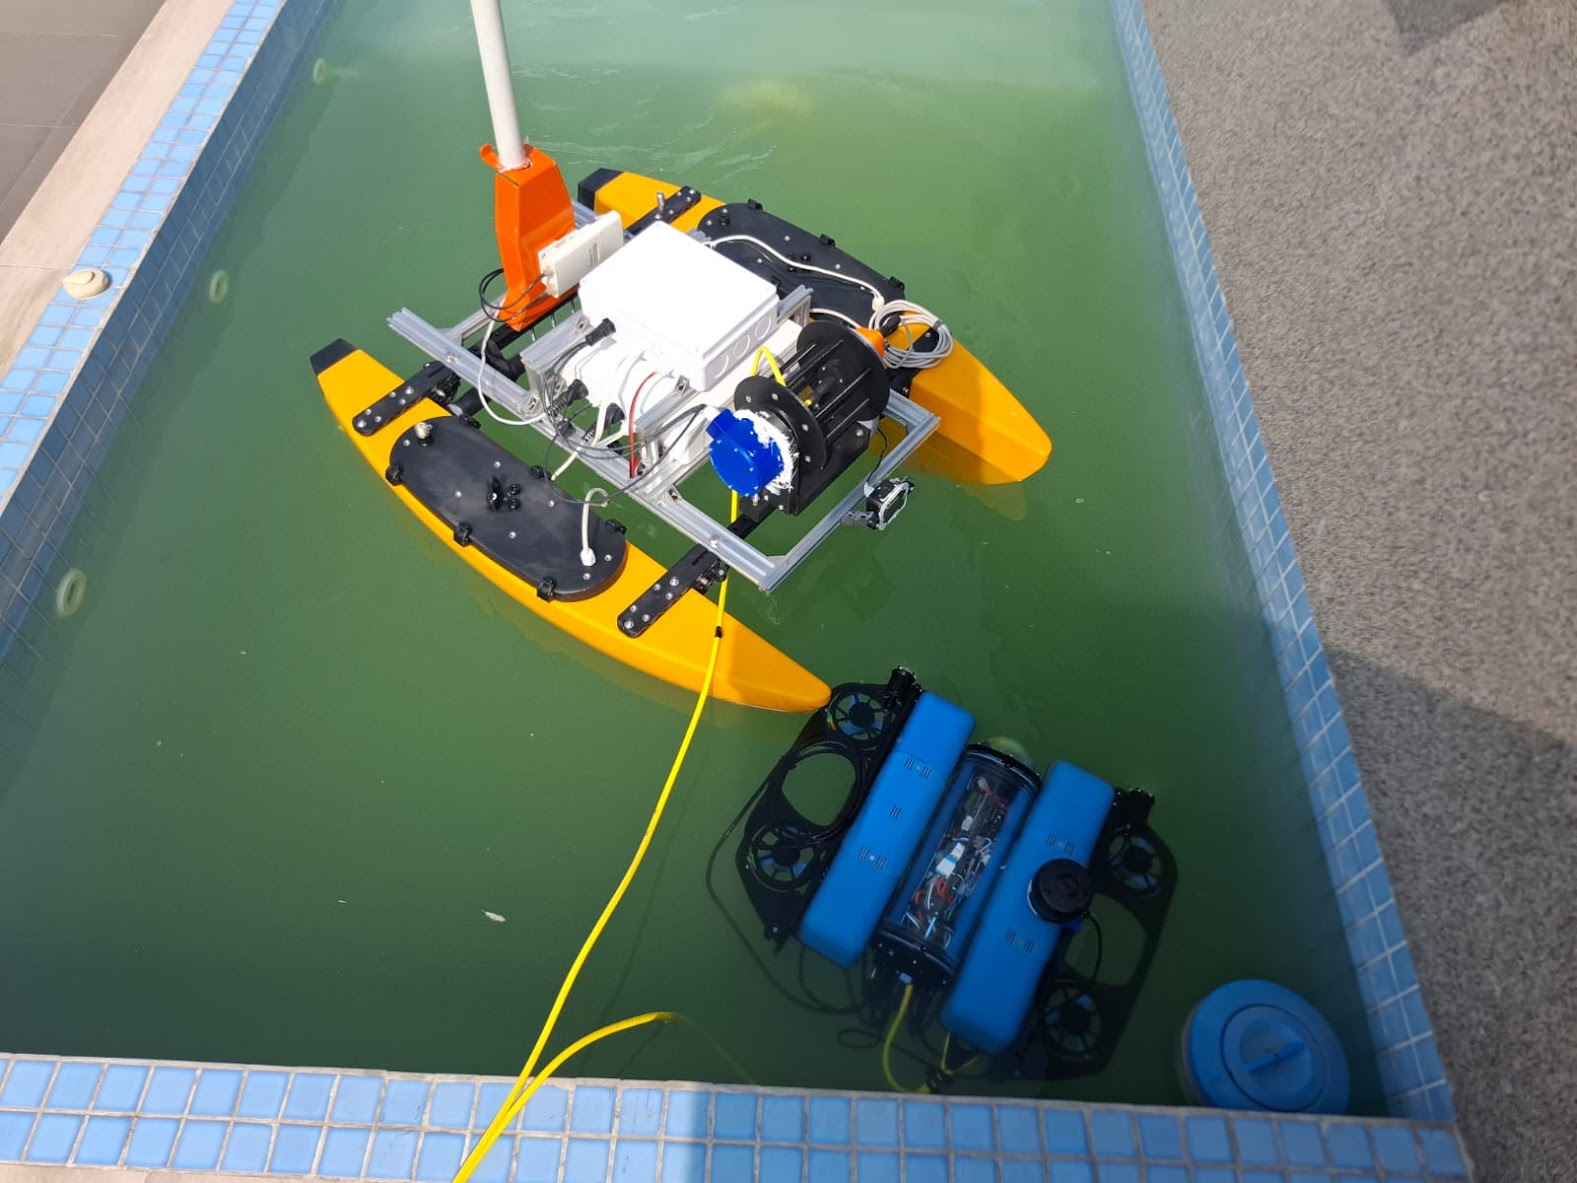
UUV STACK (ROS 2 JAZZY)
Located in UUV_ws/real_ws. Built on Ubuntu 24.04 LTS and ArduSub 4.5.7. Features MAVLink UDP 14552 bridge, Ping360 sonar filtering, Water Linked A50 DVL odometry, custom PyQt dashboard, and GUIDED sequence execution with safety timeouts.
USV STACK (ROS 2 HUMBLE)
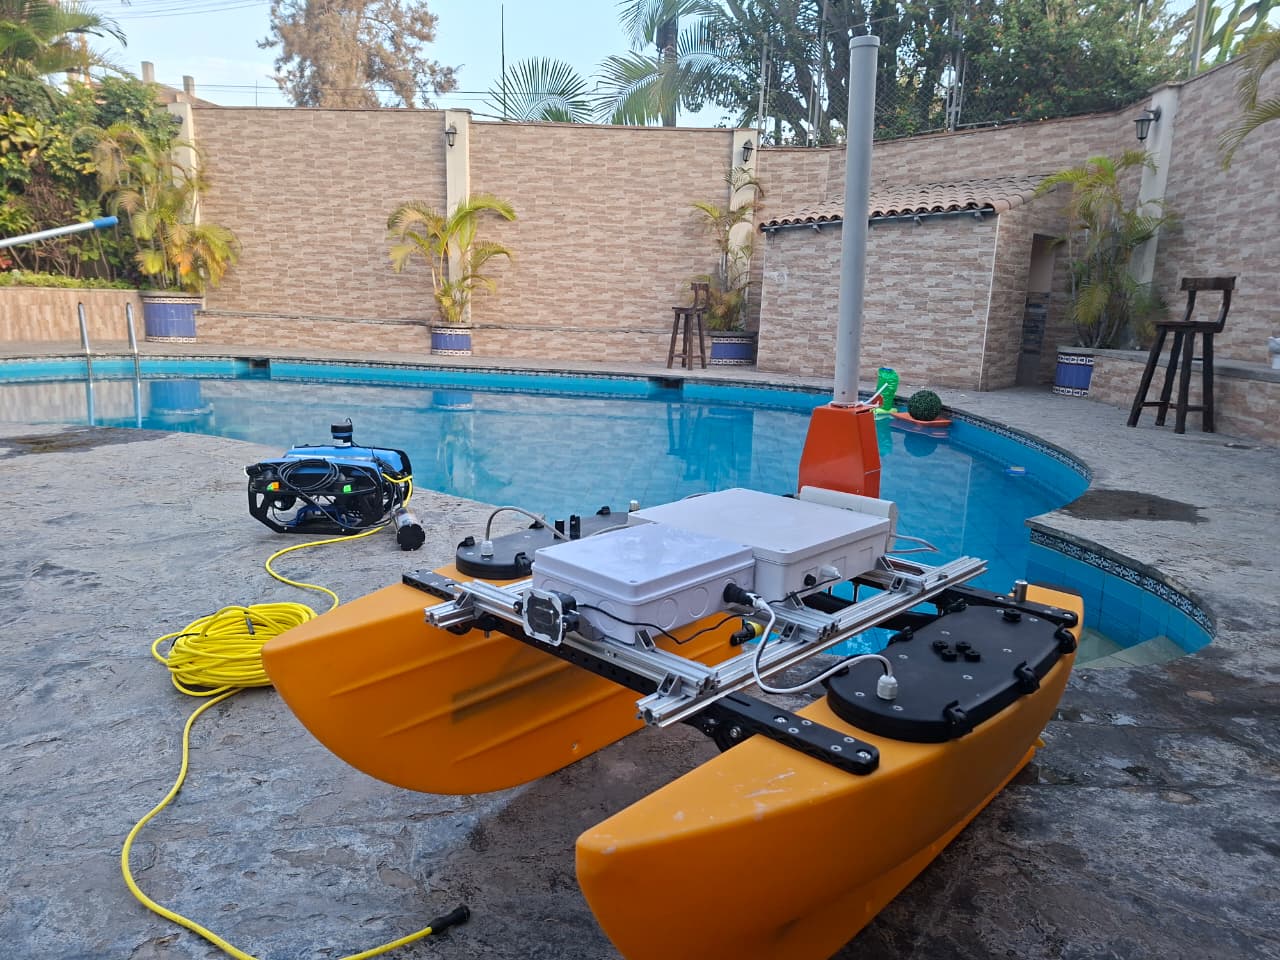
Located in USV_ws. Manages the BlueBoat platform on ArduPilot 4.6.3 STABLE. Implements read-only MAVLink UDP 14553 bridge, CAN MG6010 motor reel interface, beacon system, and Xbox deadman safety teleoperation.
SYSTEM_WS (SHARED USBL)
Located in SYSTEM_ws. Integrates the SeaTrac X150/X110 USBL acoustic positioning system through BlueOS UDP 15000 bridge. Features ROS 2 drivers for freshwater (0.0 ppt) and seawater (35.0 ppt) profiles and relative tracking.
Standard Operating Procedures (SOP) & Checklists:
To ensure field safety and reproducible data logging, our repository includes standard procedures, ROS bag automated scripts (record_pool.sh), unit test suites, and preflight checklists for pool trials.
View Complete SOPs & Operational Documentation →
Connect with our engineering leads to learn more about our open-source maritime robotics software or support our journey to RobotX 2026.
Team Tumi Robotics
Empowering PUCP students to build advanced autonomous systems for complex maritime environments.